Tooling / Custom Assemblies
Custom gripper tooling for robotic handling.
SVS materials show mounting-frame, arm and tooling-element design for application-specific robot handling. Begin with the part and required motion before defining an assembly.
Application brief
Robot make and model · part envelope and weight · pickup surfaces · access constraints · orientation changes · available services
01 / Frame and mounting design
Build the concept around real interfaces.
The supplied gripper concept shows a mounting frame and arms. Confirm flange, loading, reach, part geometry and equipment interfaces for the specific application before treating it as a build specification.
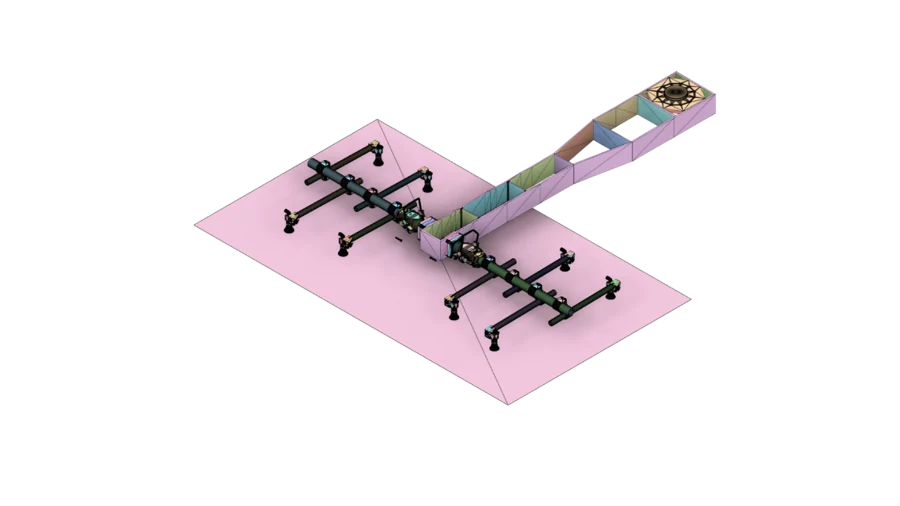
Concept rendering; no finished assembly or installation is attributed to this image.
02 / Engineering analysis
Evaluate the proposed assembly.
Centre of gravity and moment of inertia appear in the supplied gripper study. An approved, readable output must identify the exact assembly and revision. Robot payload compatibility requires application-specific checks.
Analysis output pending
Confirm assumptions, mass properties, robot model and the assembly represented before showing a result.
03 / Tooling elements
Choose elements by interface and duty.
Source materials include quick-change arrangements, brackets, clamps, swivel arms, cup holders and connectors. The photographed machined item below is unidentified; it is not labelled as a specific model or as the finished CAD concept.
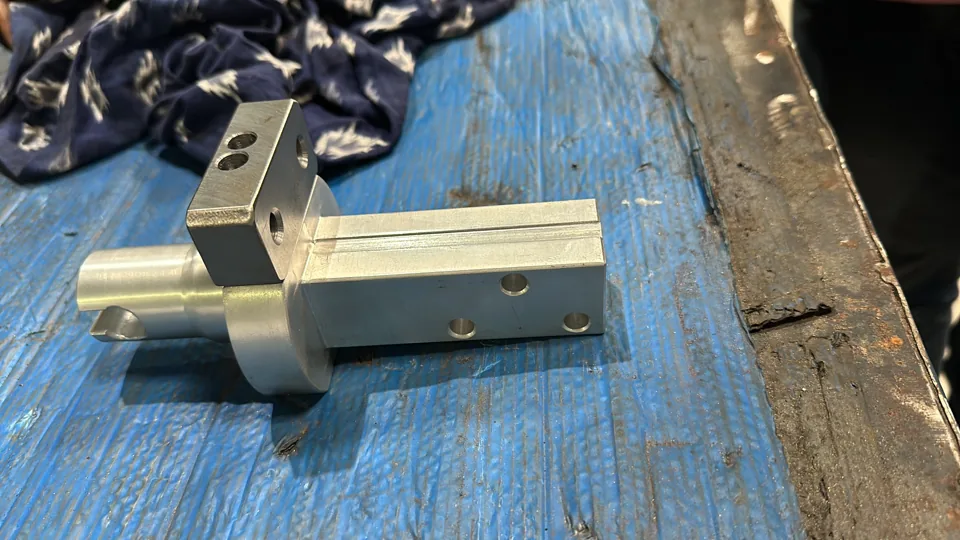
Separate component photograph; exact part identity and supply role remain unconfirmed.
04 / Manufacture and assembly
Confirm what is made, sourced and assembled.
Workshop images and component examples need part identification before they support a manufacturing claim. Material, tolerance, inspection and assembly details belong to an approved product or project record.
Delivery scope pending
Confirm in-house processes, outsourced steps, inspection records and one complete assembly example.
05 / Integration evidence
Relate the tool to a confirmed press application.
Dynamic Tandem materials illustrate tooling in a press-line workflow. Project identity, current status and which tool belongs to which installation require confirmation before an installed example is shown.
Request a tooling quote
Describe the handling sequence.
Send the robot model, payload requirement, part drawing or dimensions, weight, surface, available services and quantity for review.